Preprint · 2026
Off-Road Navigation & Terrain-Aware PlanningAdapting Generalist Vehicle Models for High-Speed MPC Across Terrains
Rwik Rana, Jesse Quattrociocchi, Christian Ellis, Nathan Tsoi, Garrett Warnell, Joydeep Biswas
arXiv preprint arXiv:2607.13319, 2026
Abstract
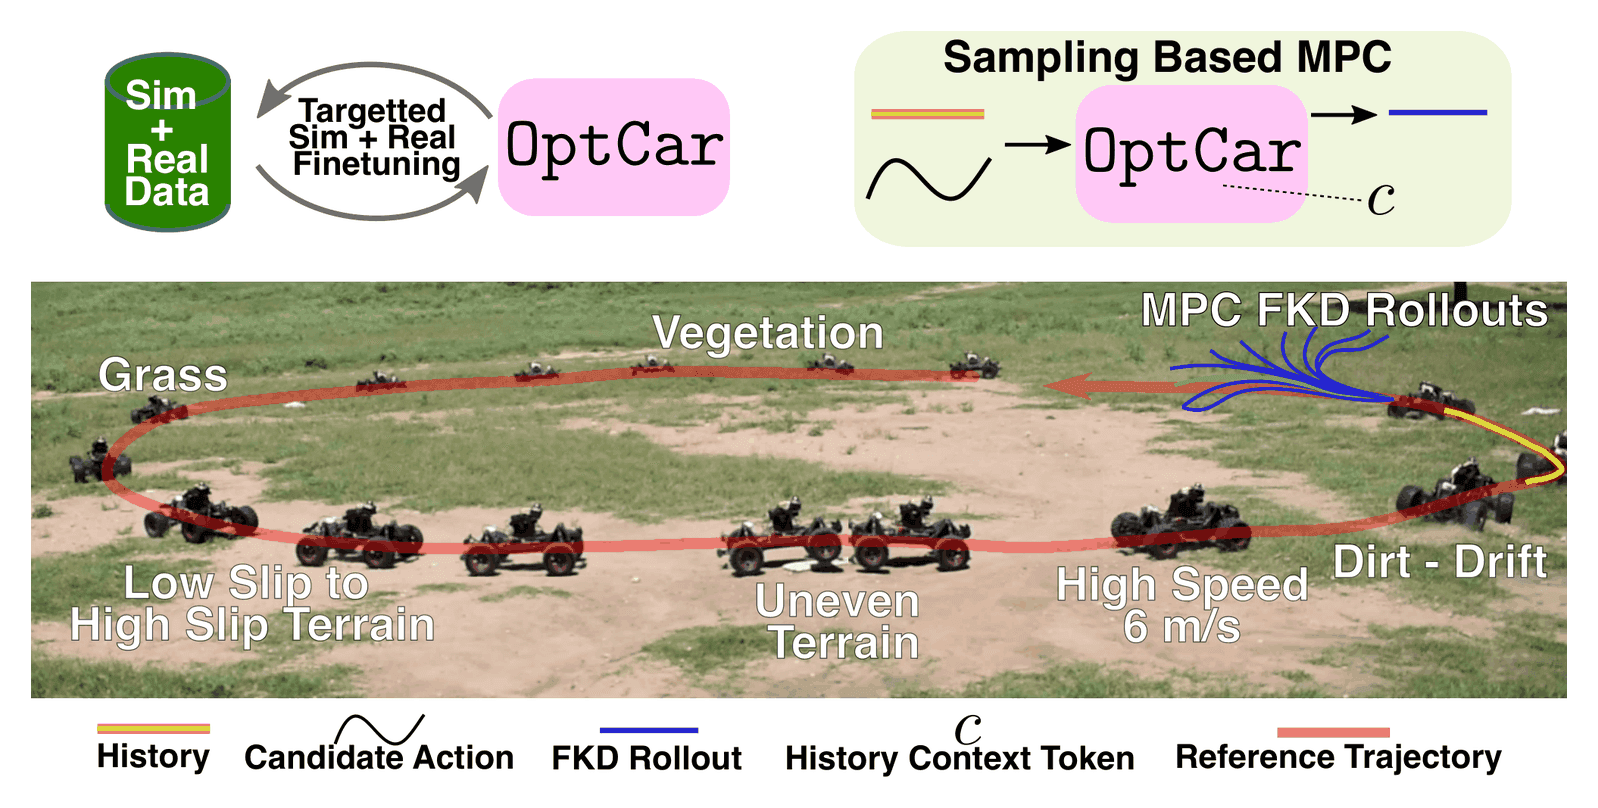
High-speed off-road autonomy requires precise closed-loop control for a target vehicle while remaining robust across changing terrains. Recent forward kinodynamic (FKD) prediction foundation models suggest a promising path, starting from a generalist model and specializing it to the target platform. However, effective specialization remains challenging, as it often requires substantial real-world data, and models adapted to one setting can still overfit to specific terrains or driving regimes. We present OptCar (Optimized Car), a recipe for bridging the gap from generalist to specialist FKD models that preserves cross-terrain generalization while optimizing performance for a specific vehicle. OptCar introduces a transformer FKD architecture that uses FiLM to condition multi-step predictions on a single dynamics context token summarizing recent state-action history. It then specializes the generalist model using limited real-world data and targeted synthetic rollouts from environment-specific system identification. In closed-loop model predictive control (MPC) experiments across three terrains and an out-of-distribution cart-pulling task, the largest gains appear at 6 m/s, the highest speed evaluated and the regime in which slip dominates tracking error. On vegetation + dirt, the most slip-diverse terrain, OptCar reduces 6 m/s trajectory tracking error by roughly 55% relative to AnyCar fine-tuned on real data alone, and remains the most accurate even when an unseen cart payload changes the dynamics. With 5 minutes of real data per terrain, OptCar is competitive on road with a specialist trained on 30 minutes of road data and outperforms it when the terrain changes. Project Page : https://amrl.cs.utexas.edu/optcar/
Cite
@misc{rana2026adapting,
  title = {{Adapting Generalist Vehicle Models for High-Speed MPC Across Terrains}},
  author = {Rwik Rana and Jesse Quattrociocchi and Christian Ellis and Nathan Tsoi and Garrett Warnell and Joydeep Biswas},
  year = {2026},
  eprint = {2607.13319},
  archivePrefix = {arXiv}
}