Conference paper · 2026
Perception & Localization in Unstructured EnvironmentsBEV-Patch-PF: Particle Filtering with BEV-Aerial Feature Matching for Off-Road Geo-Localization
Dongmyeong Lee, Jesse Quattrociocchi, Christian Ellis, Rwik Rana, Amanda Adkins, Adam Uccello, Garrett Warnell, Joydeep Biswas
2026 IEEE International Conference on Robotics and Automation (ICRA), pp. 2449-2456, 2026
Abstract
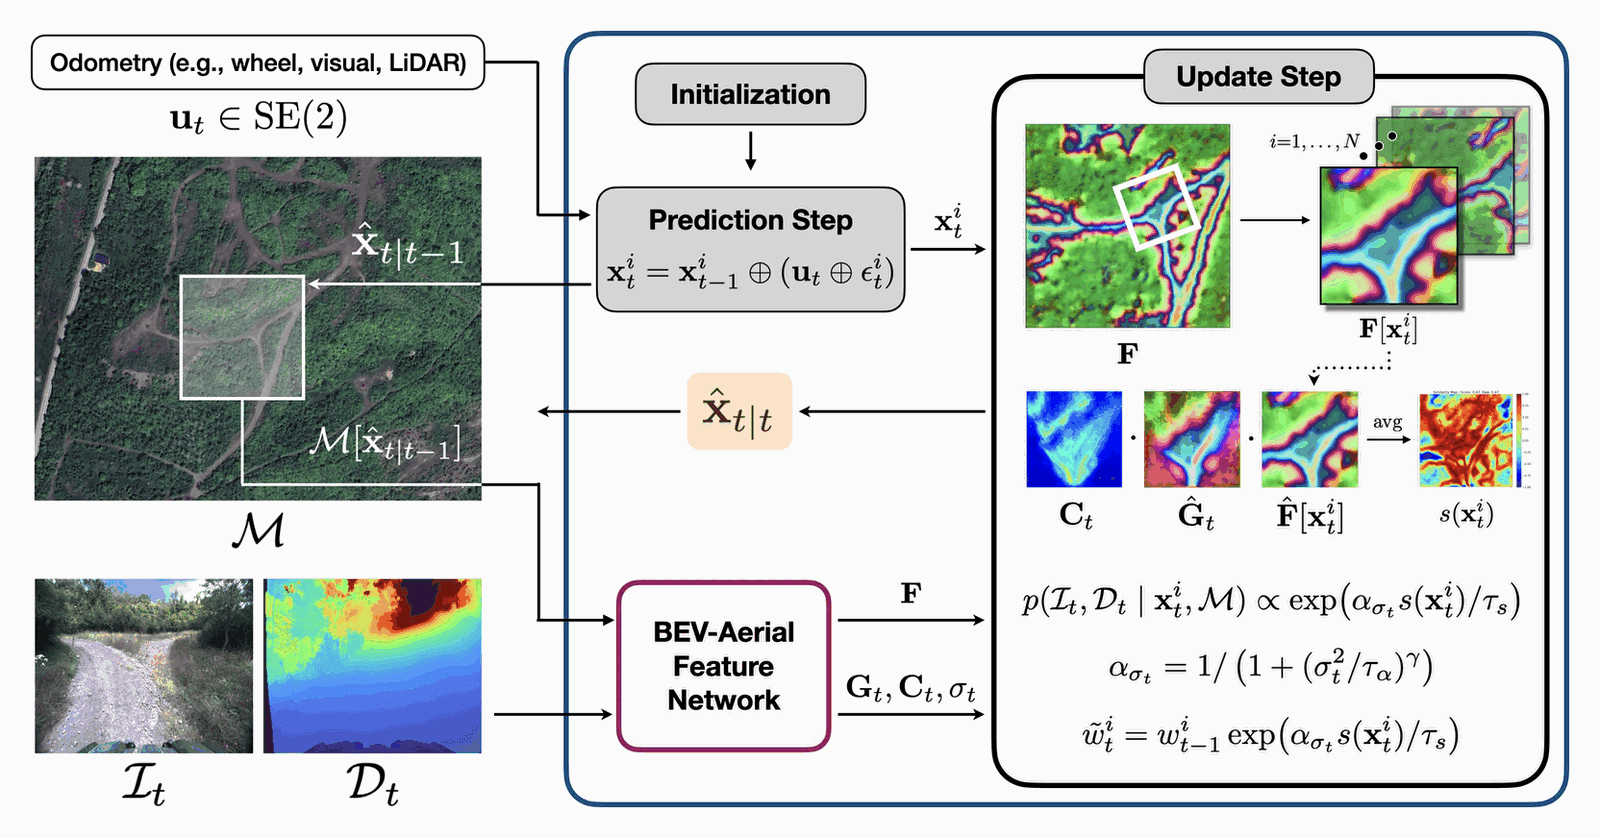
We propose BEV-Patch-PF, a GPS-free sequential geo-localization system that integrates a particle filter with learned bird's-eye-view (BEV) and aerial feature maps. From onboard RGB and depth images, we construct a BEV feature map. For each 3-DoF particle pose hypothesis, we crop the corresponding patch from an aerial feature map computed from a local aerial image queried around the approximate location. BEV-Patch-PF computes a per-particle log-likelihood by matching the BEV feature to the aerial patch feature. On two real-world off-road datasets, our method achieves 9.7x lower absolute trajectory error (ATE) on seen routes and 6.6x lower ATE on unseen routes than a retrieval-based baseline, while maintaining accuracy under dense canopy and shadow. The system runs in real time at 10 Hz on an NVIDIA Tesla T4, enabling practical robot deployment.
Cite
@inproceedings{lee2026patch,
  title = {{BEV-Patch-PF: Particle Filtering with BEV-Aerial Feature Matching for Off-Road Geo-Localization}},
  author = {Dongmyeong Lee and Jesse Quattrociocchi and Christian Ellis and Rwik Rana and Amanda Adkins and Adam Uccello and Garrett Warnell and Joydeep Biswas},
  year = {2026},
  booktitle = {2026 IEEE International Conference on Robotics and Automation (ICRA)},
  pages = {2449--2456},
  doi = {10.1109/icra57385.2026.11696885}
}