Workshop paper · 2026
Foundation Models for Embodied AIMOSAIC: The Right Modules for Each Task in Embodied Agents
Kevin Wang, Dweep Trivedi, Vincent Ha, Albert Jiang, Christian Ellis, Ufuk Topcu, Swarat Chaudhuri, Zhangyang Wang
The 2nd Workshop on Foundation Models Meet Embodied Agents at CVPR 2026, 2026
Abstract
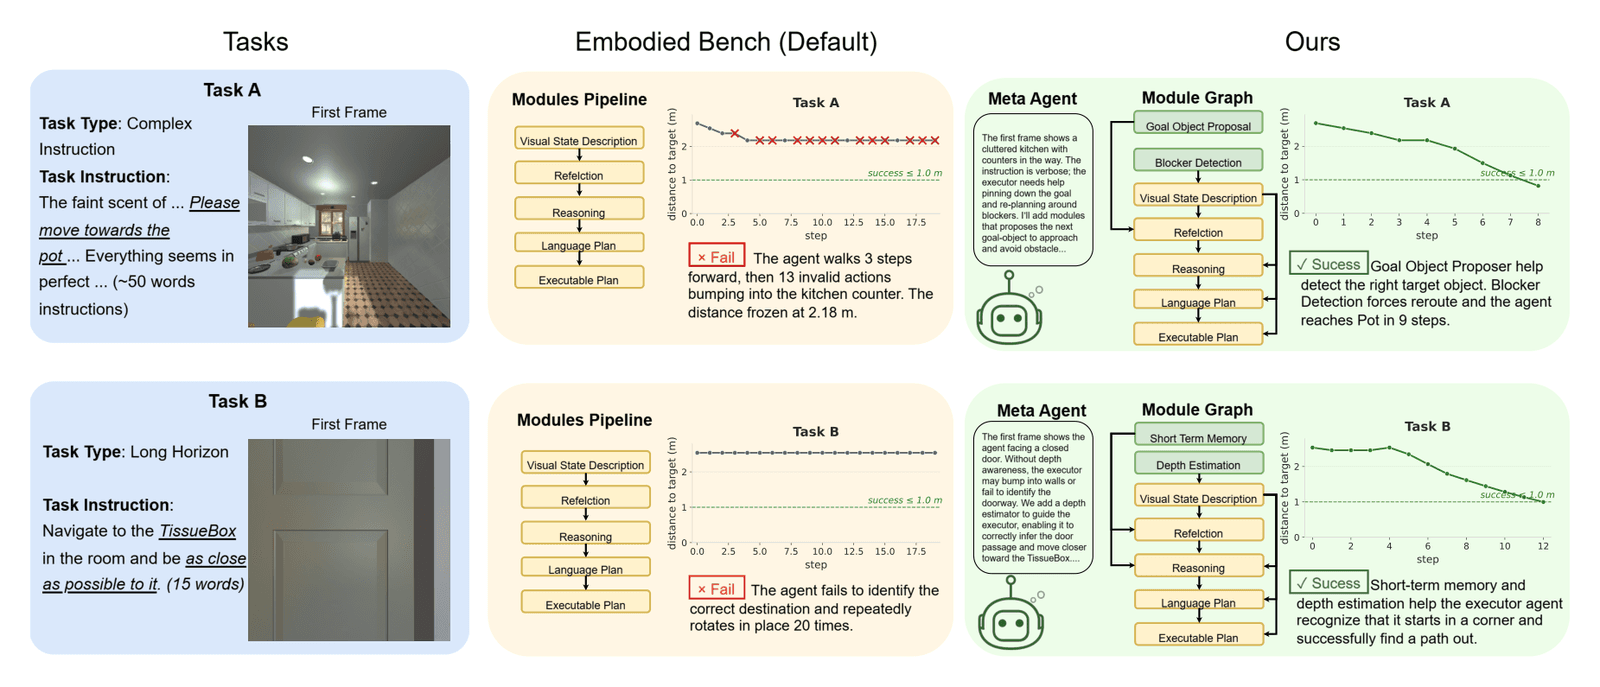
Embodied agents demand a heterogeneous mix of capabilities: spatial precision for manipulation, persistent mapping for long-horizon navigation, and multi-step planning under natural-language instruction. The dominant remedy folds every such capability into one foundation model through spatial pre-training and geometry-aware fine-tuning, shipping a single fixed pipeline for every task in the benchmark. We contend that the question is not how to grow capability into the model, but how to compose, per task, the context that lets the model's existing capability bear on the task at hand. We formulate embodied agent design as per-task module-graph synthesis: a joint search over which modules to include, which concrete tool implements each, and how each tool's parameters bind to environment observations and upstream outputs. Solving this search by full self-evolution is infeasible in embodied control, where validating each candidate requires a multi-step rollout and credit arrives only at episode end. We therefore introduce MOSAIC, a memory-conditioned agent that retains the load-bearing slice of self-evolution and drops the rest: the typed module catalog, the meta-agent, and the model weights stay fixed, while a memory of past pipeline designs and their outcomes evolves with deployment. A frontier meta-agent runs once per episode to compose a pipeline conditioned on retrievals from this memory, and a small executor runs every step. On EB-Nav, MOSAIC reaches 50.0% average success across five capability subsets, an 18.4% gain over the default EmbodiedBench agent at the same Qwen3-VL-8B backbone and +5.3% over a baseline that activates every module in the same catalog without per-task selection.
Cite
@inproceedings{wang2026mosaic,
  title = {{MOSAIC: The Right Modules for Each Task in Embodied Agents}},
  author = {Kevin Wang and Dweep Trivedi and Vincent Ha and Albert Jiang and Christian Ellis and Ufuk Topcu and Swarat Chaudhuri and Zhangyang Wang},
  year = {2026},
  booktitle = {The 2nd Workshop on Foundation Models Meet Embodied Agents at CVPR 2026}
}