Conference paper · 2021
Learning from Demonstration & Reinforcement LearningRisk Averse Bayesian Reward Learning for Autonomous Navigation from Human Demonstration
Christian Ellis, Maggie Wigness, John G. Rogers III, Craig Lennon, Lance Fiondella
2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 8928-8935, 2021
Abstract
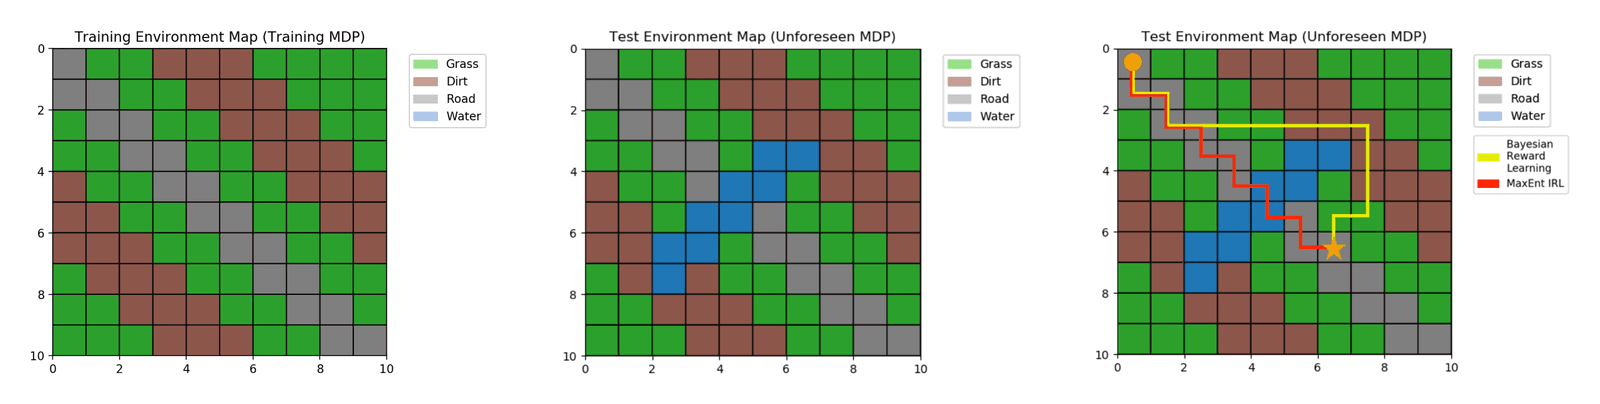
The study presents a Bayesian approach to reward learning for autonomous navigation systems, emphasizing risk aversion and learning from human demonstrations to improve navigation safety and efficiency.
Cite
@inproceedings{ellis2021risk,
  title = {{Risk Averse Bayesian Reward Learning for Autonomous Navigation from Human Demonstration}},
  author = {Christian Ellis and Maggie Wigness and John G. Rogers III and Craig Lennon and Lance Fiondella},
  year = {2021},
  booktitle = {2021 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  pages = {8928--8935},
  doi = {10.1109/iros51168.2021.9635835}
}