Preprint · 2025
Off-Road Navigation & Terrain-Aware PlanningZero to Autonomy in Real-Time: Online Adaptation of Dynamics in Unstructured Environments
William Ward, Sarah Etter, Jesse Quattrociocchi, Christian Ellis, Adam J. Thorpe, Ufuk Topcu
arXiv preprint arXiv:2509.12516, 2025
Abstract
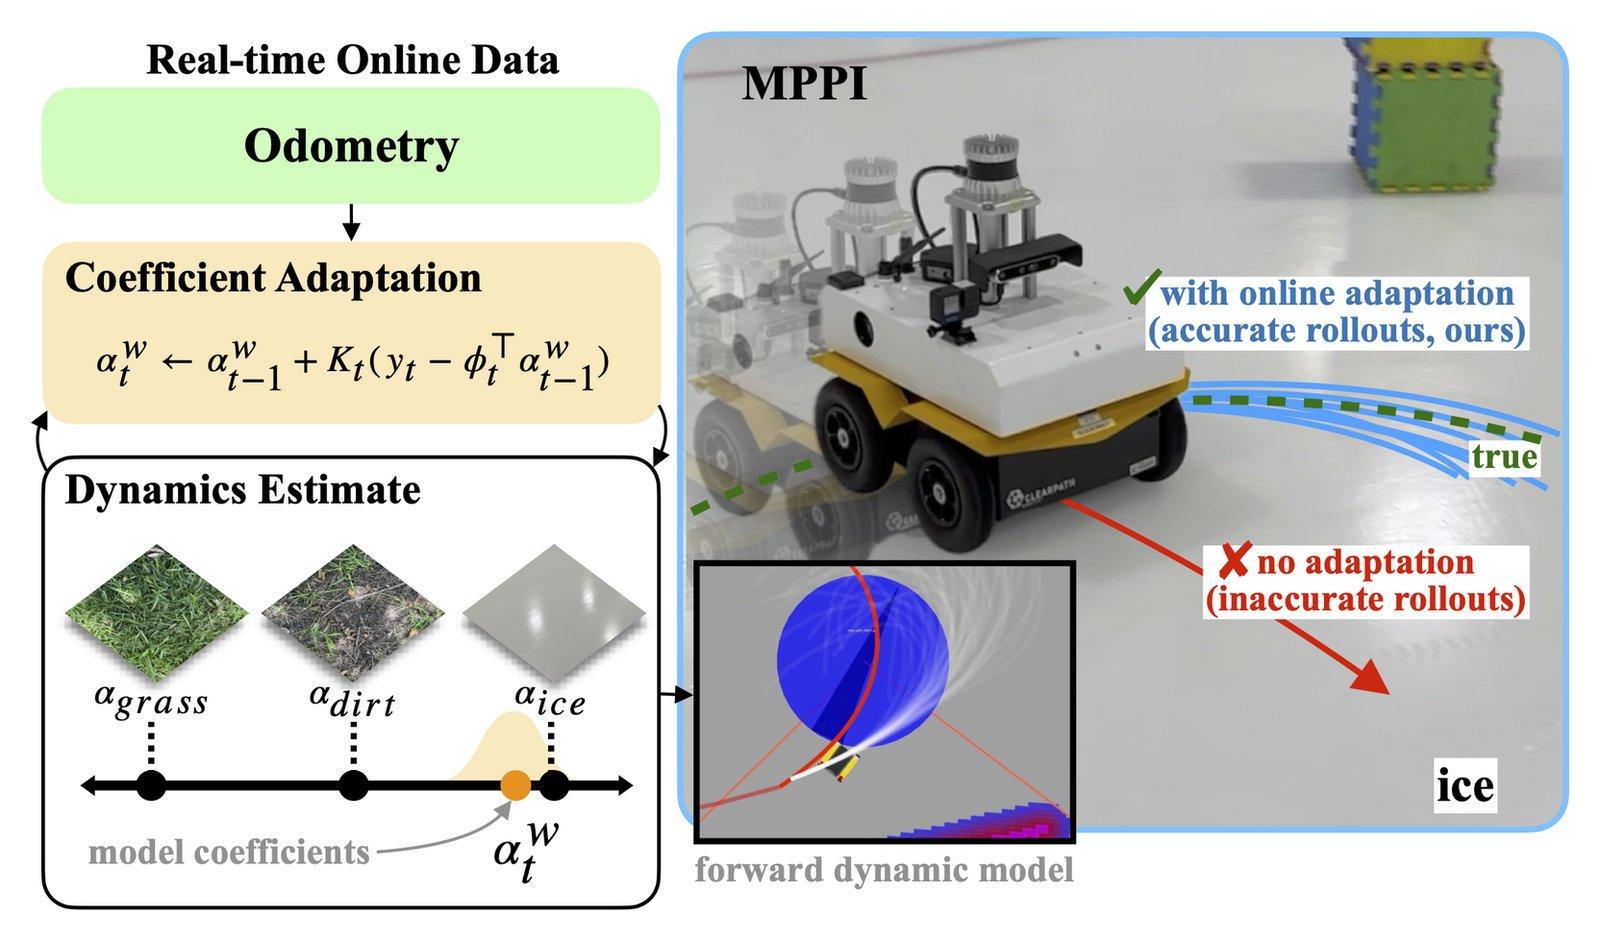
Autonomous robots must go from zero prior knowledge to safe control within seconds to operate in unstructured environments. Abrupt terrain changes, such as a sudden transition to ice, create dynamics shifts that can destabilize planners unless the model adapts in real-time. We present a method for online adaptation that combines function encoders with recursive least squares, treating the function encoder coefficients as latent states updated from streaming odometry. This yields constant-time coefficient estimation without gradient-based inner-loop updates, enabling adaptation from only a few seconds of data. We evaluate our approach on a Van der Pol system to highlight algorithmic behavior, in a Unity simulator for high-fidelity off-road navigation, and on a Clearpath Jackal robot, including on a challenging terrain at a local ice rink. Across these settings, our method improves model accuracy and downstream planning, reducing collisions compared to static and meta-learning baselines.
Cite
@misc{ward2025zero,
  title = {{Zero to Autonomy in Real-Time: Online Adaptation of Dynamics in Unstructured Environments}},
  author = {William Ward and Sarah Etter and Jesse Quattrociocchi and Christian Ellis and Adam J. Thorpe and Ufuk Topcu},
  year = {2025},
  eprint = {2509.12516},
  archivePrefix = {arXiv}
}